机器人扭矩关节执行单元Robot Torque Joint Actuator

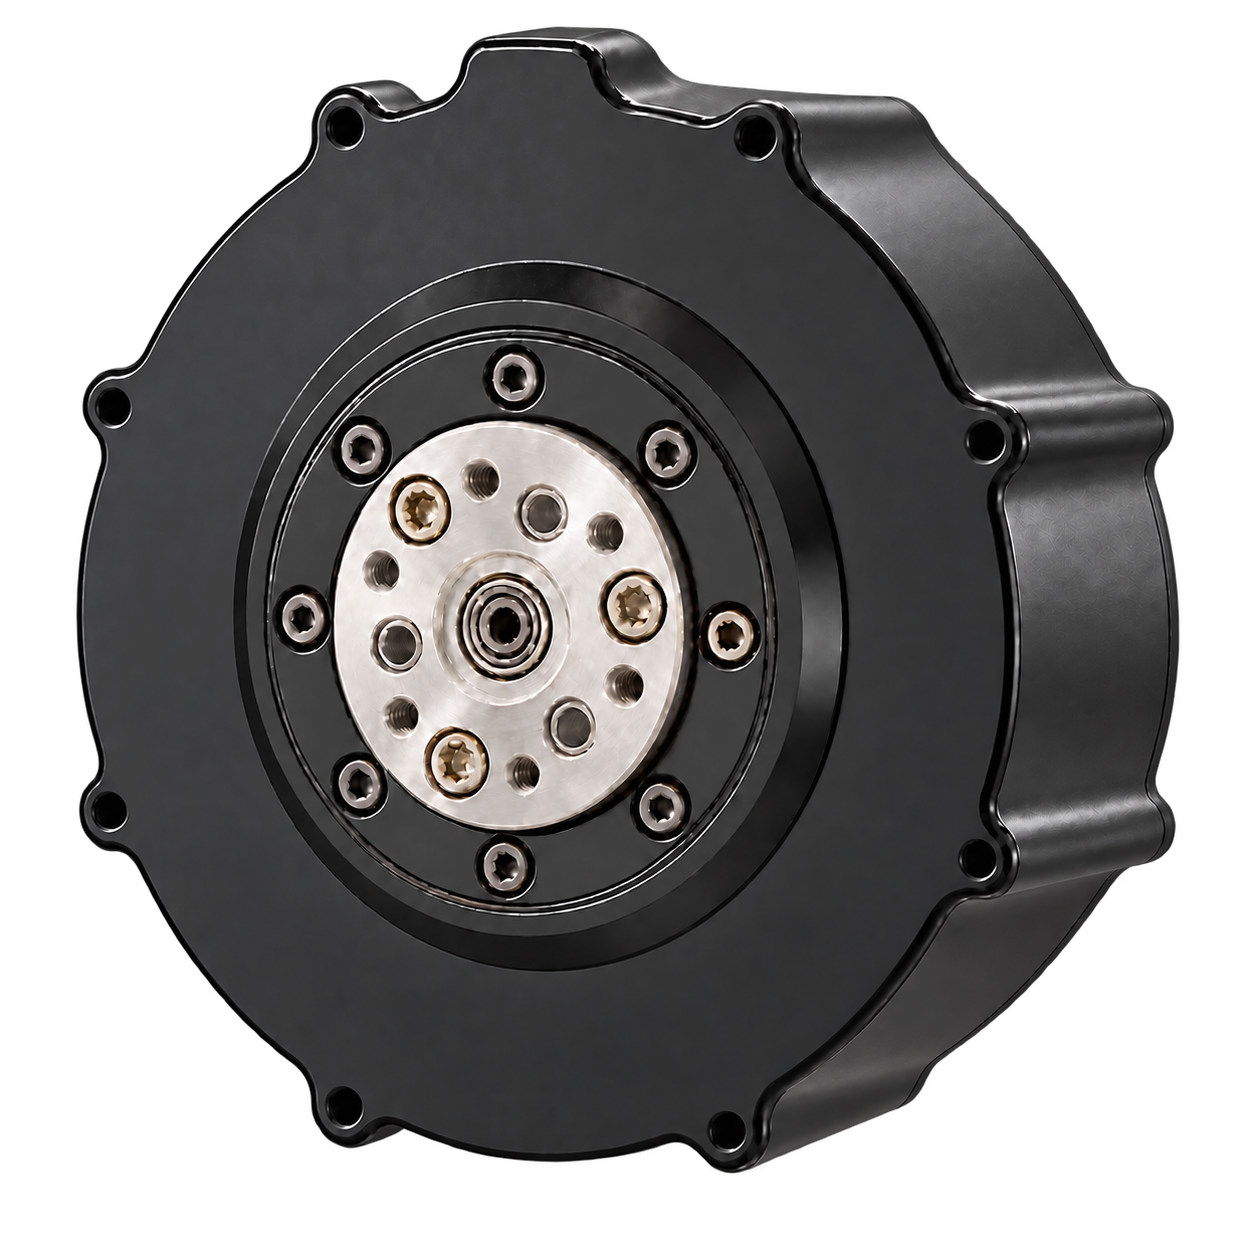
SANPO J8108-R8

面向机械臂、腿足机器人和机器人扭矩关节的一体化关节电机,集成电机、FOC 驱动、绝对值编码器、减速器和多总线通信接口。An integrated joint motor for robotic arms, legged robots, and high-torque robot joints, combining the motor, FOC drive, absolute encoder, reducer, and multi-bus communication interfaces.

一体化 FOC 驱动Integrated FOC Drive集成电机 FOC 控制驱动,减少外部驱动器和系统接线。Integrates the motor FOC drive to reduce external controllers and system wiring.
16 位绝对值编码器16-bit Absolute Encoder集成高精度 16 位绝对值编码器,用于关节位置与运动控制。Integrates a high-precision 16-bit absolute encoder for joint positioning and motion control.
8 倍减速器8:1 Reducer电机、驱动器、编码器和 8 倍减速器集成为完整关节执行单元。Combines the motor, drive, encoder, and 8:1 reducer into a complete joint actuator.
多总线通信Multi-bus Communication支持 FDCAN、CAN 和 RS485 协议通信,适配不同机器人控制系统。Supports FDCAN, CAN, and RS485 communication for different robot control systems.
多轴同步控制Synchronized Multi-axis Control支持 FDCAN 多轴组控和同步控制,适用于多关节机器人。Supports FDCAN group control and synchronized operation for multi-joint robots.
开放协议插件Open Protocol Plugins支持自定义协议插件,并可使用开源社区提供的兼容协议插件。Supports custom protocol plugins and compatibility plugins contributed by the open-source community.
使用说明User Guide
SANPO J8108-R8 integrated joint motor

调试工具Debugging Tools

USB 串口直连Direct USB Serial Connection

电机配置工具Motor Configuration Tool

通过电机 USB 调试口直连,在浏览器中查看电机状态、配置参数和调试运动模式。Connect directly to the motor USB debug port to view status, configure parameters, and test motion modes in the browser.

  • 支持电机状态查看、ID 配置、温控配置、失联配置等View motor status and configure the motor ID, thermal control, and communication-loss protection.
  • 支持速度、位置、电流、MIT 运控等模式调试Test speed, position, current, and MIT motion-control modes.
  • 支持固件更新、通信协议插件安装等Update firmware and install communication protocol plugins.
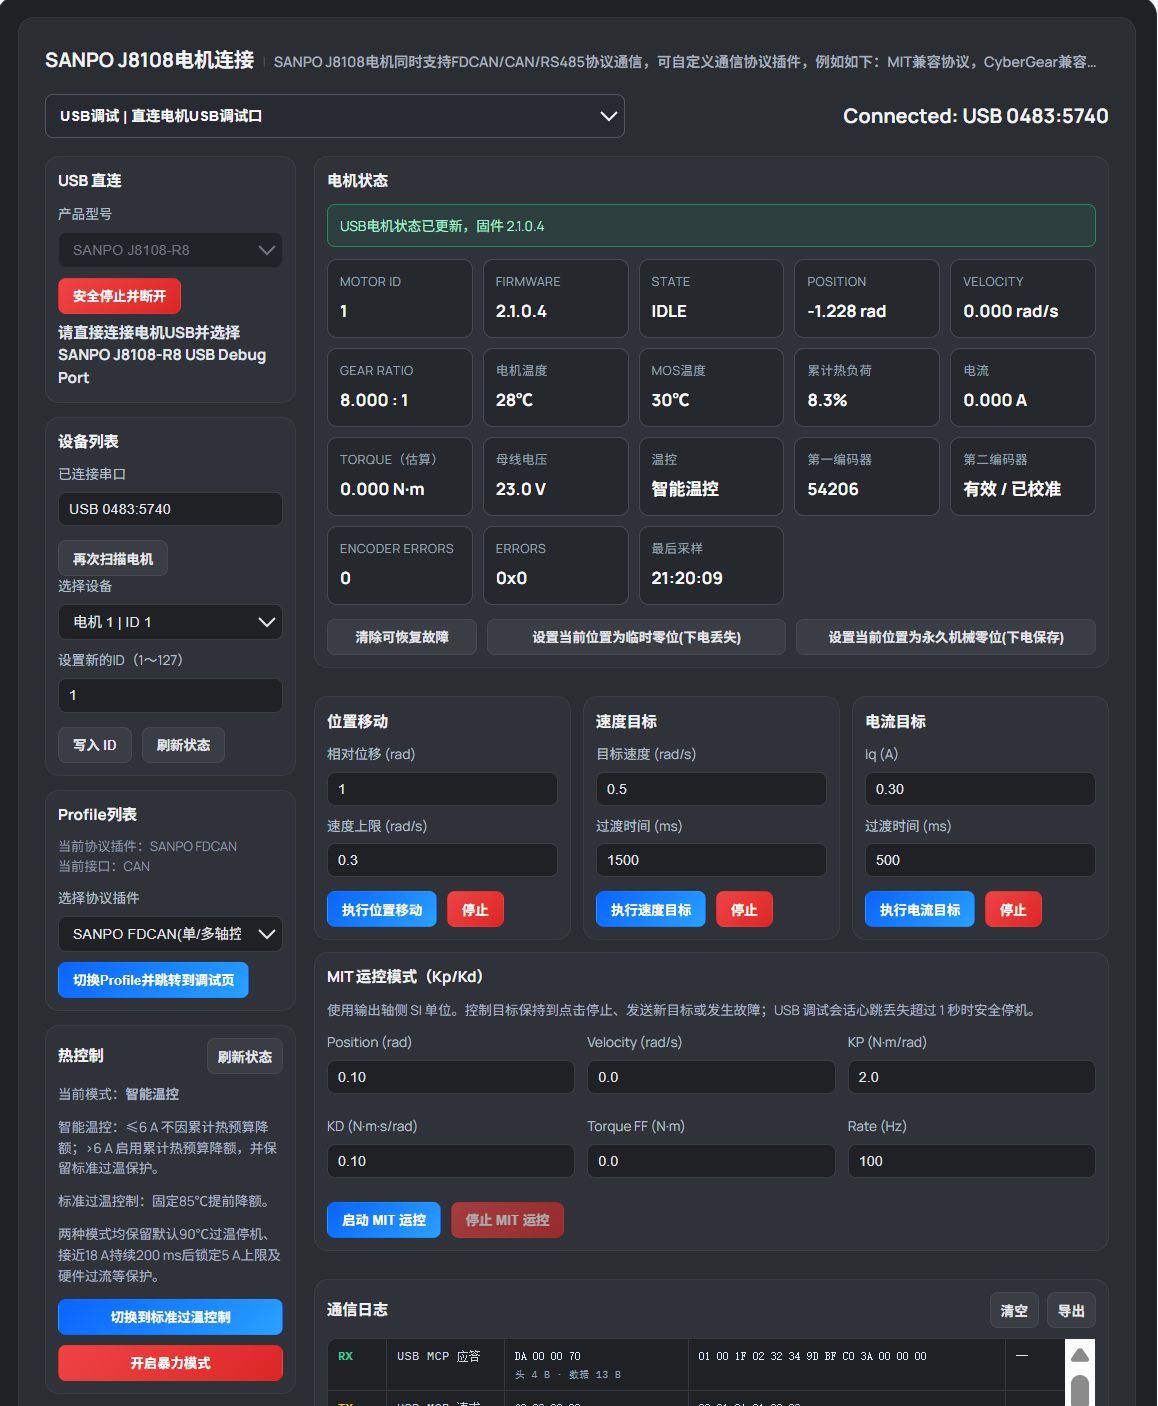
SANPO J8108-R8 USB configuration and debugging interface
通过 SANPO SPINE 连接Connection via SANPO SPINE

电机通信协议调试工具Motor Protocol Debugging Tool

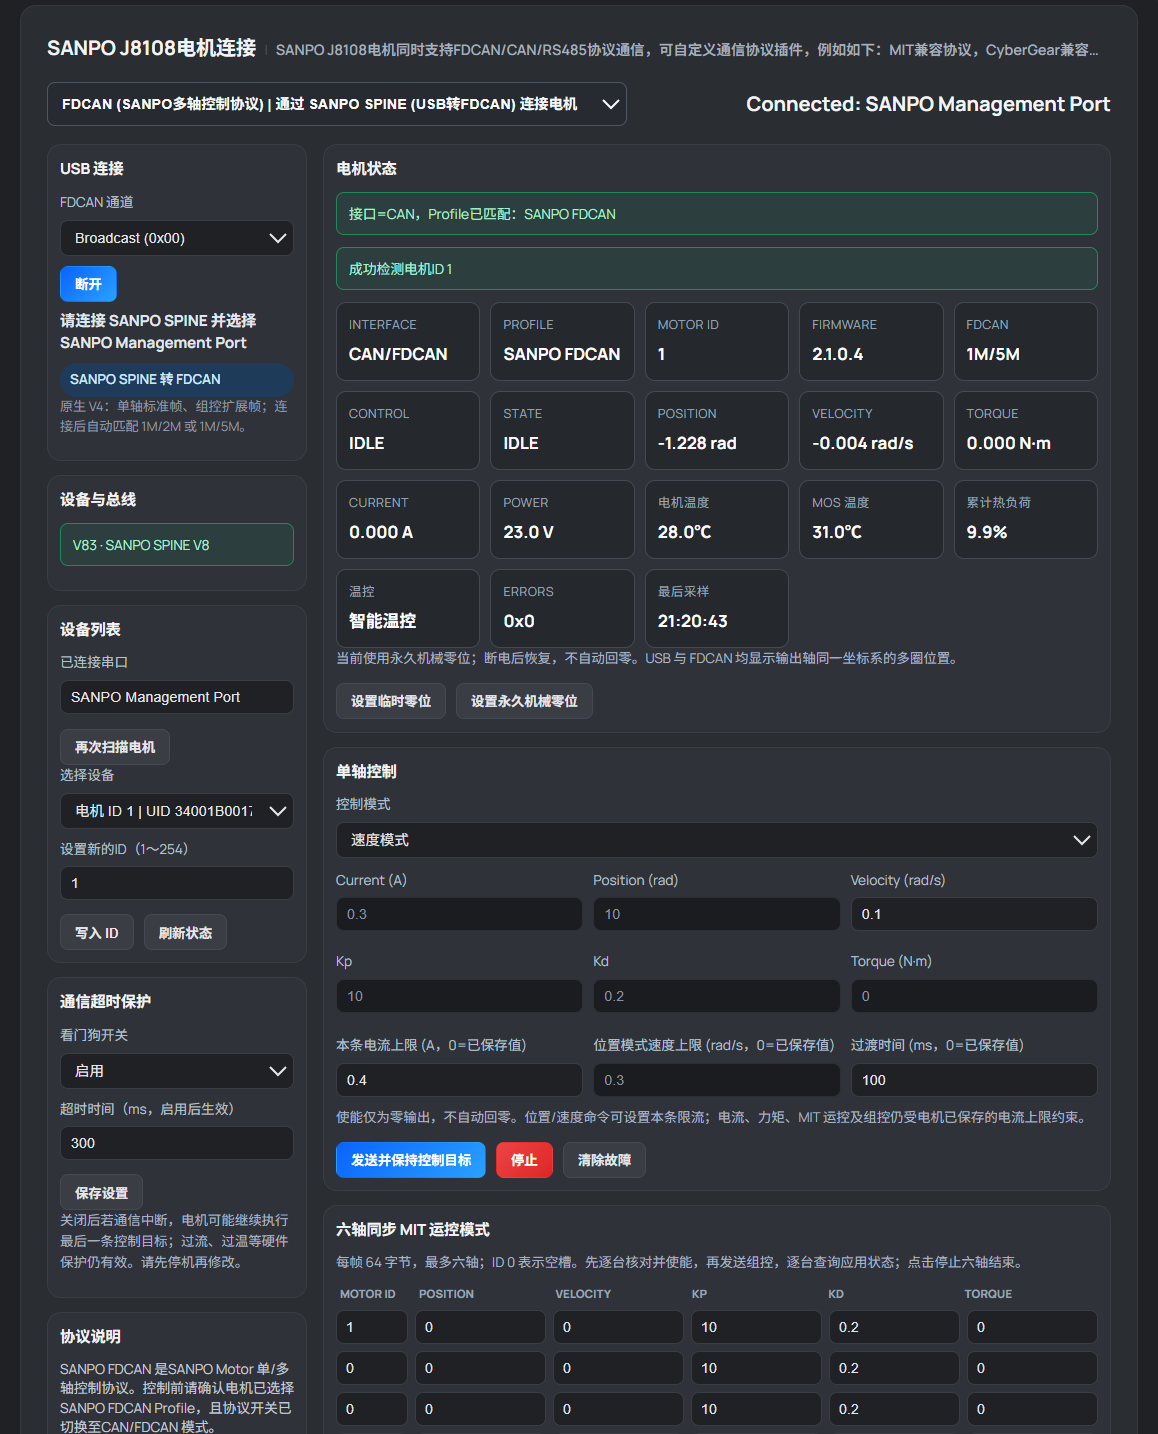
通过 SANPO SPINE 连接电机,测试 FDCAN/CAN/RS485 通信协议与电机控制。Connect the motor through SANPO SPINE to test FDCAN/CAN/RS485 protocols and motor control.

  • 支持 FDCAN 协议测试,以及速度、位置、电流、力矩、MIT 运控模式测试Test the FDCAN protocol and speed, position, current, torque, and MIT motion-control modes.
  • 支持 FDCAN 多电机组控测试Test FDCAN group control with multiple motors.
  • 支持兼容协议测试,例如 MIT CAN、CyberGear CAN、GM8010 RS485 等协议Test compatibility protocols, including MIT CAN, CyberGear CAN, and GM8010 RS485.
SANPO J8108-R8 FDCAN protocol and multi-axis control interface

文档下载Document Downloads

共 6 项6 resources

产品说明书Product Manuals (2)

产品规格、安装接线与通信协议资料。Product specifications, installation, wiring, and protocol documents.

MAN-01

SANPO J8108-R8 产品使用说明书SANPO J8108-R8 User Manual

产品参数、接口定义、控制模式和安全注意事项。Specifications, interfaces, control modes, and safety precautions.

版本Version待发布Pending
待上传Pending
MAN-02

外形尺寸与安装说明Dimensions and Installation Guide

外形尺寸、安装孔位和机械安装要求。Dimensions, mounting holes, and mechanical installation requirements.

版本Version待发布Pending
待上传Pending

开发例程Development Examples (2)

用于快速验证连接、通信和基础控制的示例工程。Example projects for connection, communication, and basic control validation.

DEV-01

USB 直连调试例程Direct USB Debugging Example

读取状态、配置参数并执行基础控制的示例。Example for status reading, parameter configuration, and basic control.

版本Version示例Demo
待上传Pending
DEV-02

FDCAN 单/多轴控制例程FDCAN Single-/Multi-Axis Example

通过 SANPO SPINE 控制一台或多台 J8108-R8。Control one or more J8108-R8 motors through SANPO SPINE.

版本Version示例Demo
待上传Pending

其他资源Other Resources (2)

固件维护、故障排查和其他配套资料。Firmware maintenance, troubleshooting, and supporting resources.

RES-01

固件升级说明Firmware Update Guide

升级前检查、更新、校验和恢复流程。Pre-update checks, installation, verification, and recovery.

版本Version待发布Pending
待上传Pending
RES-02

常见故障排查Troubleshooting Guide

常见故障状态、检查顺序和恢复建议。Common fault states, diagnostic sequence, and recovery guidance.

版本Version待发布Pending
待上传Pending

典型应用Typical Applications

机械臂肩关节、髋关节和膝关节Shoulder, hip, and knee joints in robotic arms and legged robots
四足机器人与双足机器人扭矩关节High-torque joints for quadruped and biped robots
机器人原型开发、科研与教学平台Robot prototyping, research, and education platforms