SANPO 机器人控制系统SANPO Robot Control System

SANPO SPINE 通信集成板SANPO SPINE Communication Board适用于机器人,机械臂,机器狗,无人船等CAN/RS485设备控制场景For CAN/RS485 device control in robots, robotic arms, quadruped robots, unmanned boats, and more

电气隔离,隔离弱电控制系统和强电电机系统Electrical isolation between the low-voltage control system and high-voltage motor system实时控制通信,USB/SPI 转 CAN、FDCAN、RS485Real-time control communication: USB/SPI to CAN, FDCAN, and RS485实时设备接入,串口/IIC/ADC 等外设,例如压力传感器、陀螺仪等Real-time device access for serial, IIC, ADC, and other peripherals such as pressure sensors and gyroscopes

查看使用说明View User Guide

SANPO 一体化关节模组SANPO Integrated Joint Module适用于机器人,机械臂,机器狗,无人船等扭矩控制和精密控制场景For torque and precision control in robots, robotic arms, quadruped robots, unmanned boats, and more

集成纯 16 位高精度绝对值编码器Integrated pure 16-bit high-precision absolute encoder集成电机 FOC 控制驱动Integrated motor FOC control drive集成减速器Integrated reducer集成总线通信协议 CAN/FDCAN/RS485Integrated CAN/FDCAN/RS485 bus communication protocols

查看使用说明View User Guide
SANPO robot system
CONNECTSANPO 通信集成板SANPO SPINE Communication Board多总线通信与实时控制中枢Multi-bus communication and real-time control hub
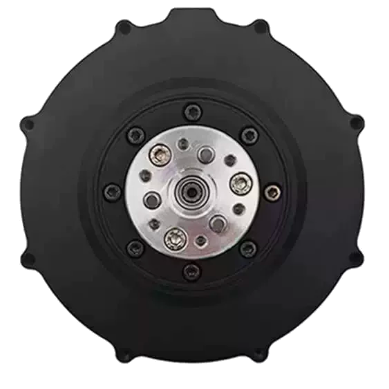
TORQUE JOINTSANPO J8108-R8SANPO J8108-R8用于肩、髋、膝等机器人扭矩关节Torque actuator for shoulder, hip, and knee joints
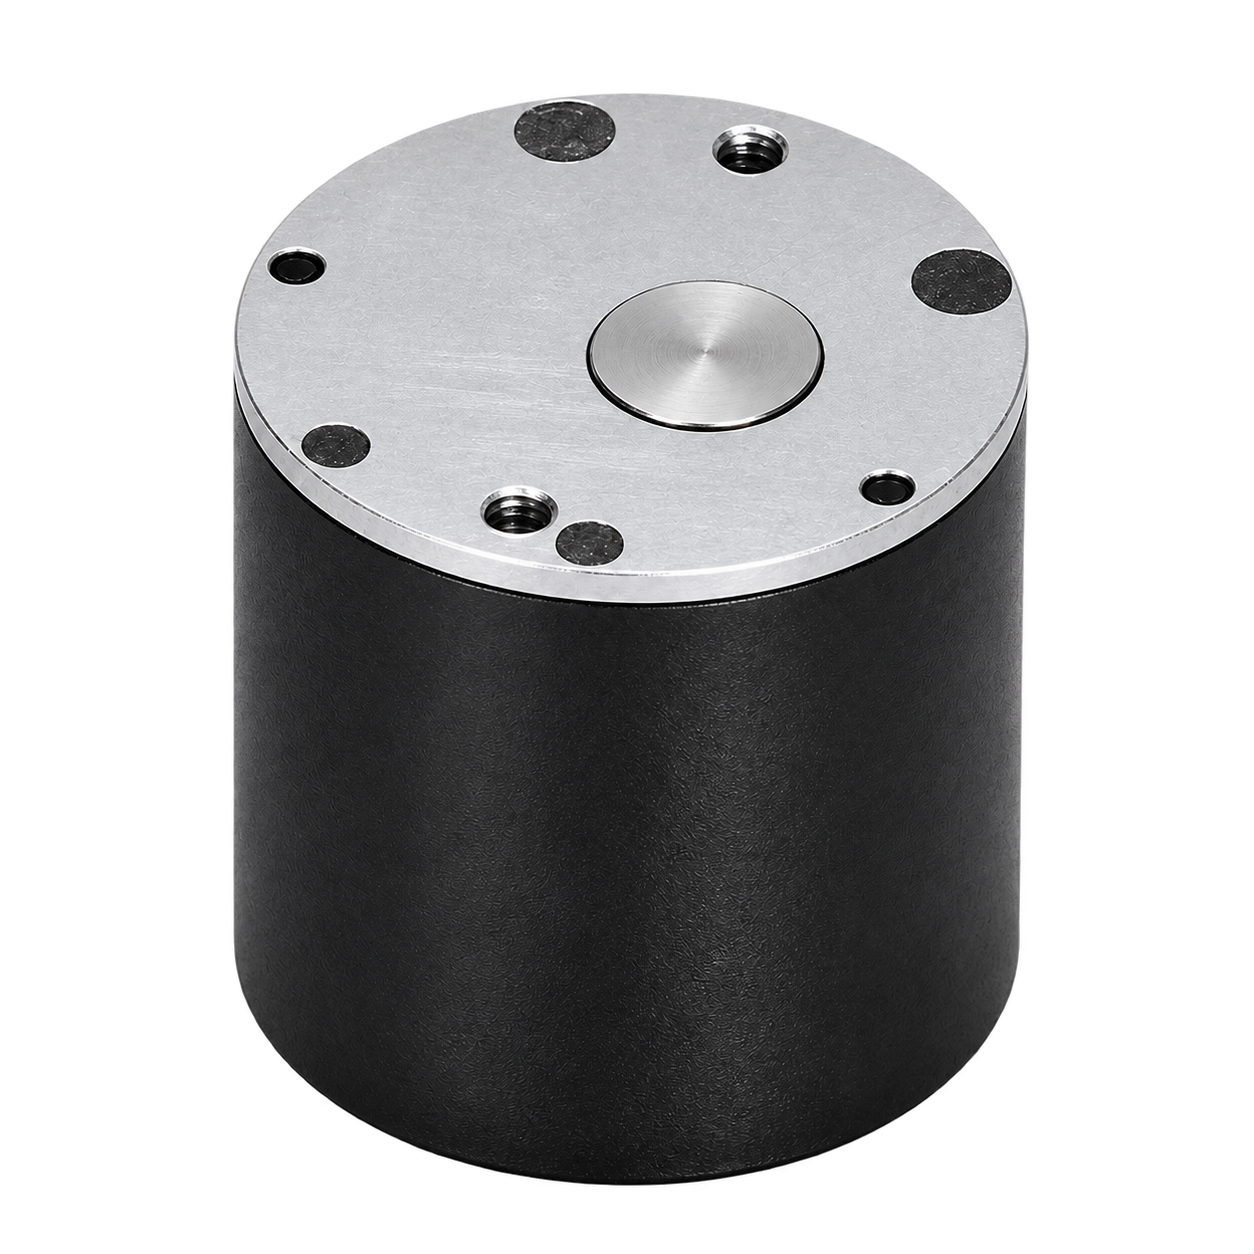
FINGER JOINTSANPO J1515-R186SANPO J1515-R186用于灵巧手的手指关节Compact actuator for dexterous robot fingers
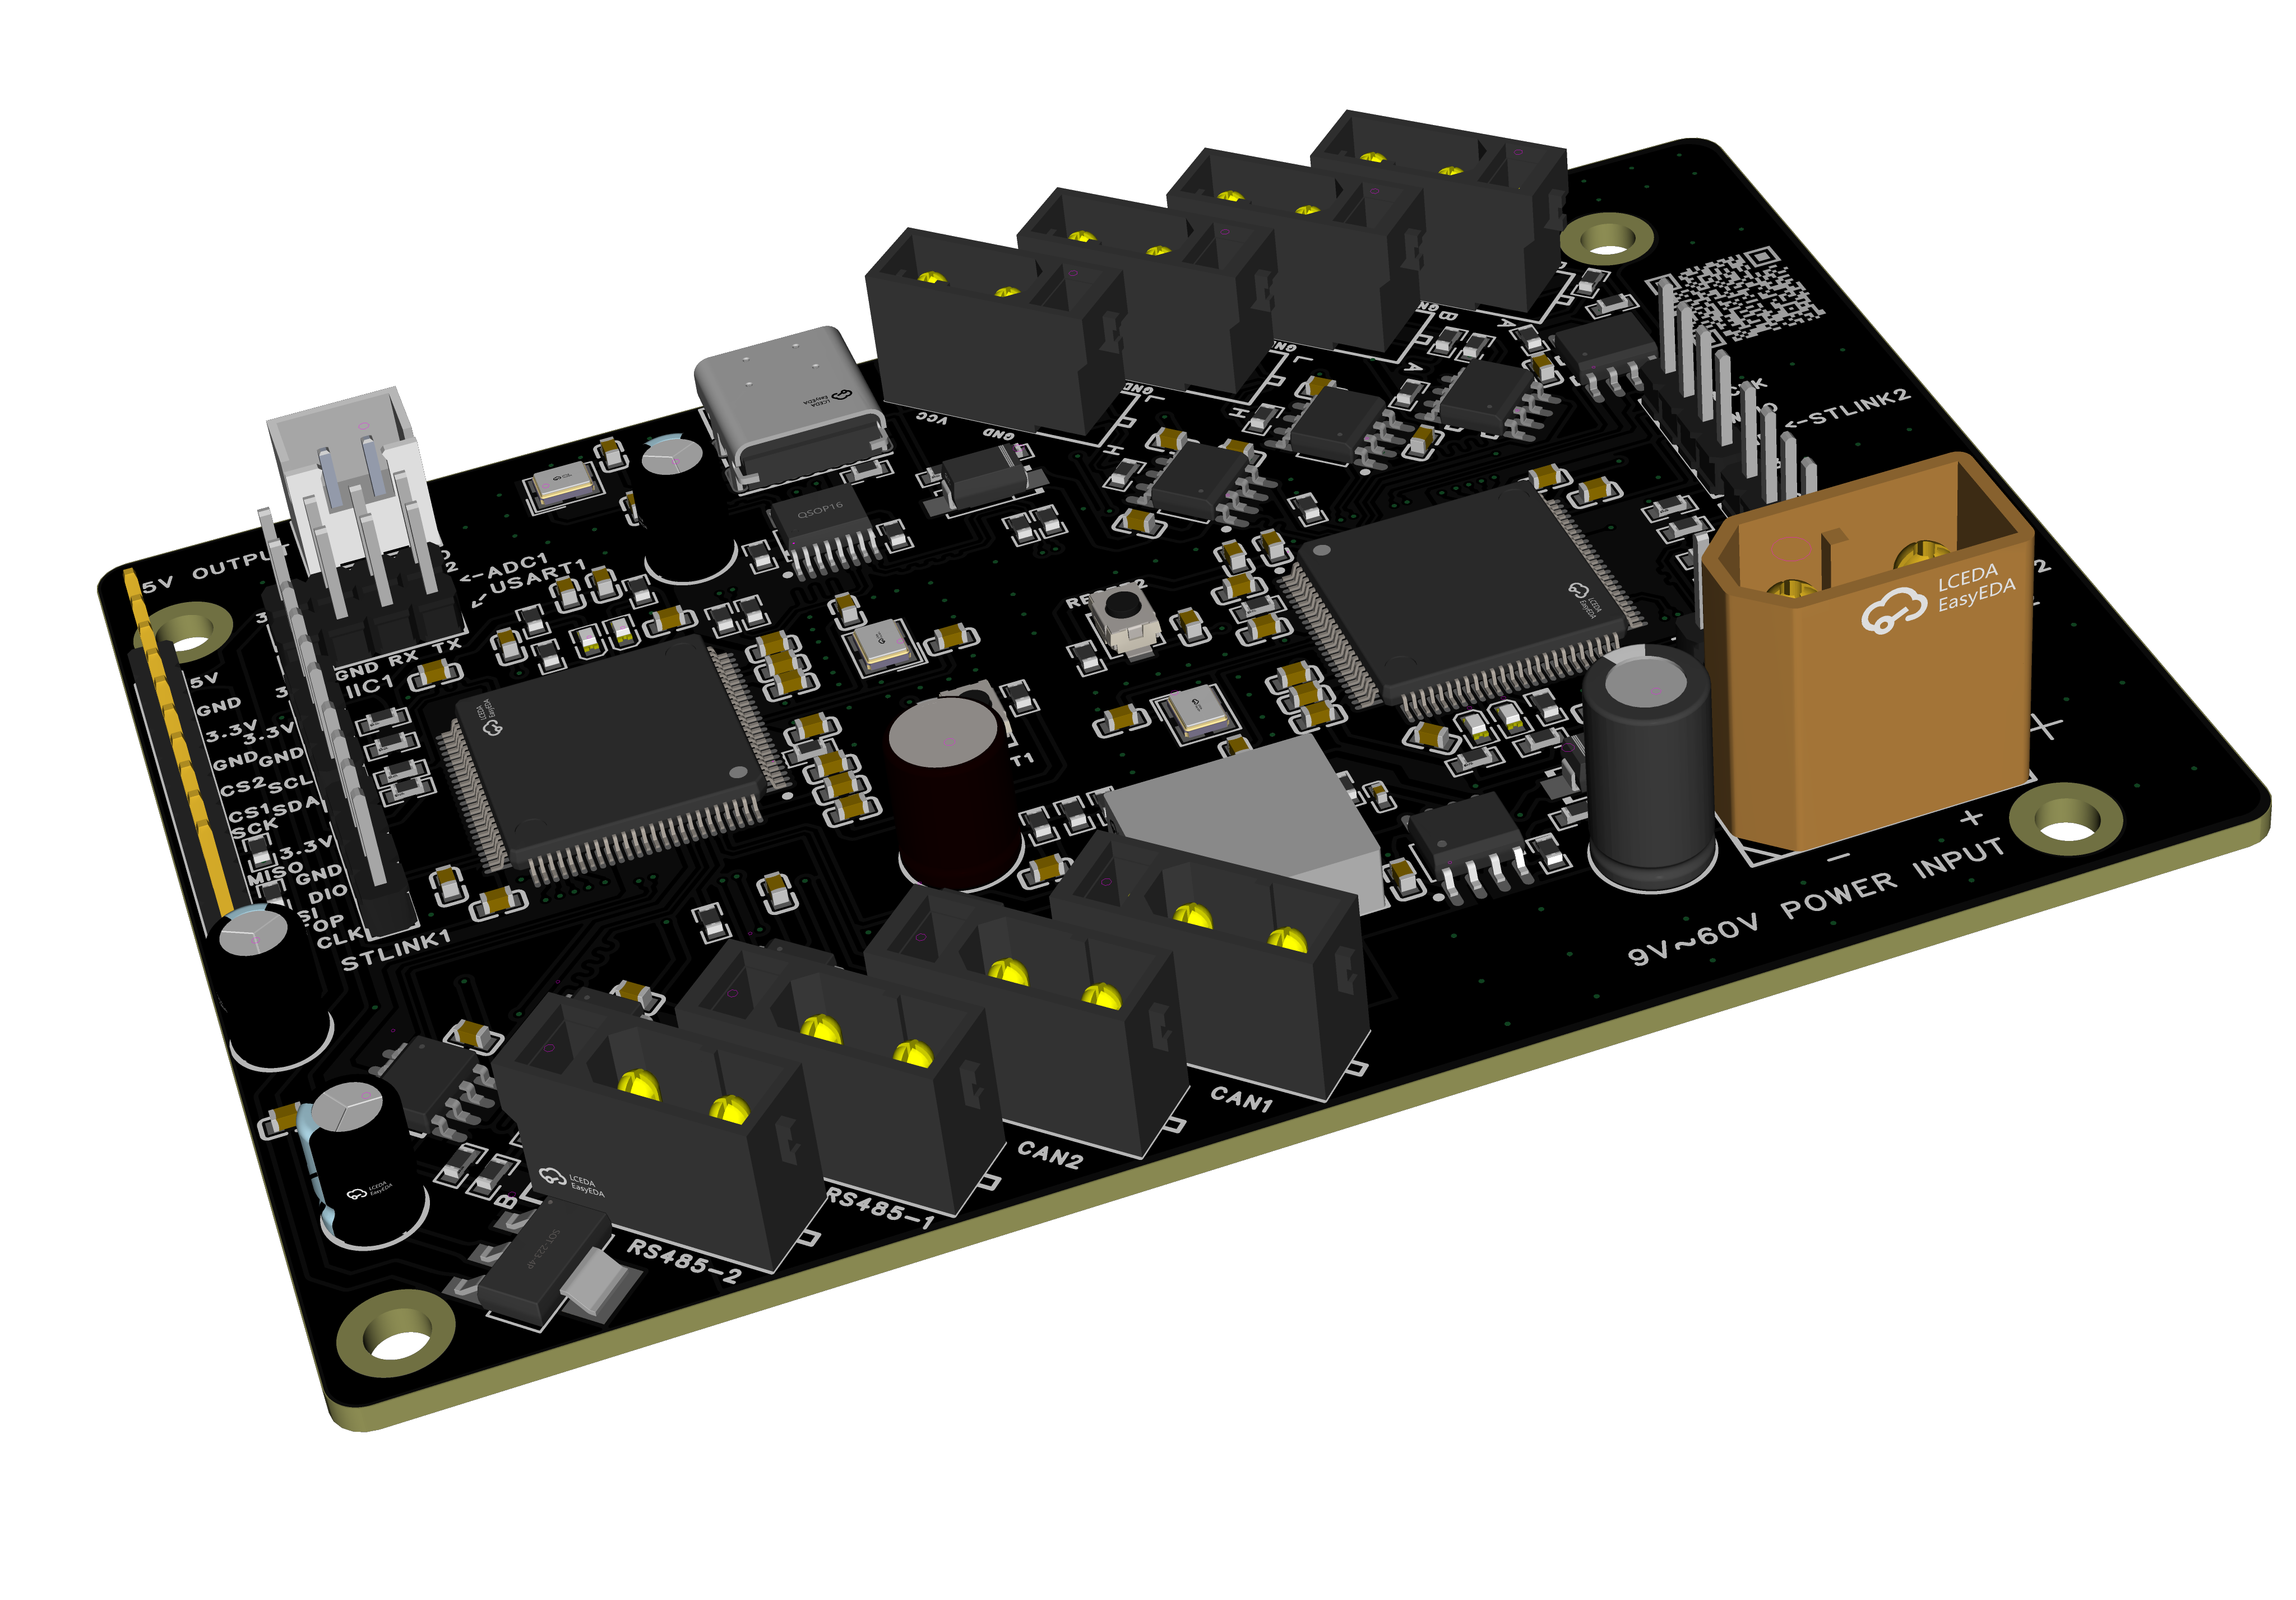
SANPO integrated communication board

SANPO SPINE 通信集成板SANPO SPINE Communication Board

SANPO SPINE 机器人集成开发板用于将电脑或主控板(树莓派/Jetson等)连接到 CAN、FDCAN 和 RS485 设备/关节电机。The SANPO SPINE robot integration board connects a computer or host controller, such as Raspberry Pi or Jetson, to CAN, FDCAN, and RS485 devices or joint motors.

控制方式Host InterfacesUSB / SPI / 串口 / 网络USB / SPI / Serial / Network
设备总线Device BusesCAN / FDCAN / RS485CAN / FDCAN / RS485
  • 支持 FDCAN/CAN/RS485 设备/电机Supports FDCAN/CAN/RS485 devices and motors
  • 多路独立总线并行控制,适合多关节机器人系统Independent multi-channel buses for multi-joint robot systems
  • 支持 USB、SPI、SocketCAN 等控制方式,适用于多种场景USB, SPI, and SocketCAN support for flexible host integration
  • 内置任务调度,可执行周期、单次和上电自动任务Built-in scheduler for periodic, one-shot, and power-on tasks
  • 支持串口,IIC,ADC等传感器外设扩展Supports serial, IIC, ADC, and other sensor connections
SANPO J8108-R8 torque joint motor
扭矩关节Torque Joint
SANPO J1515-R186 finger joint motor
手指关节Finger Joint

SANPO 一体化关节电机SANPO Integrated Joint Motors

覆盖机器人扭矩关节与灵巧手手指关节,并兼容多种通信方式和常用电机协议。Covers robot torque joints and dexterous-hand finger joints, with support for multiple communication methods and common motor protocols.

扭矩关节Torque JointSANPO J8108-R8 · 24 N/mSANPO J8108-R8 · 24 N/m
手指关节Finger JointSANPO J1515-R186SANPO J1515-R186
  • 集成FOC电机驱动,同时支持 FDCAN/CAN/RS485 协议控制Integrates FOC motor control and supports FDCAN/CAN/RS485 protocol control
  • 集成高精度16位绝对值编码器,8倍减速器Integrates a high-precision 16-bit absolute encoder and an 8:1 reducer
  • 终端电阻开关,自由切换端侧串联电机Provides a termination-resistor switch for flexible end-of-chain motor connection
  • 支持FDCAN多轴组控,多轴同步控制Supports FDCAN multi-axis group control and synchronized multi-axis control
  • 开放自定义协议插件,开源社区提供丰富的兼容协议插件,包括MIT兼容协议、CyberGear兼容协议、GM8010兼容协议、OpenARM兼容协议等Supports open custom protocol plugins, with a broad selection of compatibility plugins contributed by the open-source community, including MIT-compatible, CyberGear-compatible, GM8010-compatible, and OpenARM-compatible protocols
在线与本地工具Online and Local Tools

调试工具Debugging Tools

从浏览器快速调试到本地 CAN/FDCAN 总线分析,按使用场景选择合适工具。Choose the right tool for browser-based device debugging or local CAN/FDCAN bus analysis.

在线工具 · 无需下载Online · No download

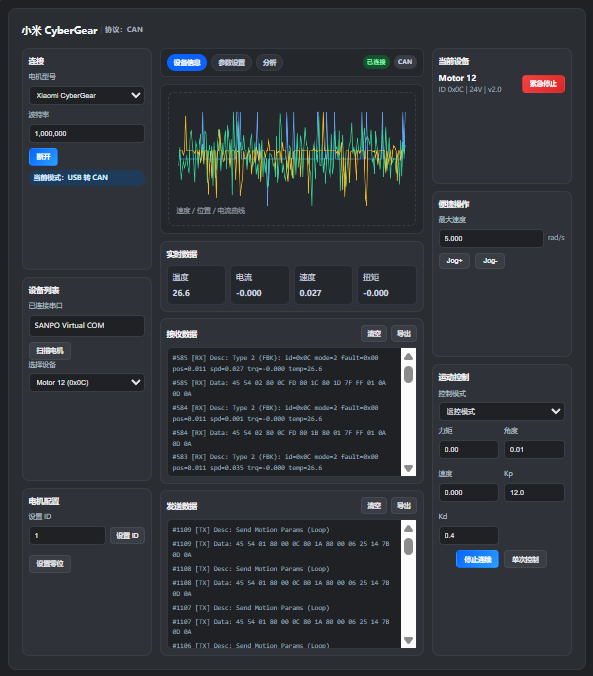
SANPO StudioSANPO Studio

直接在浏览器中连接 SANPO SPINE,调试 FDCAN/CAN/RS485 设备与 SANPO 一体化关节电机。Connect SANPO SPINE in the browser to debug FDCAN/CAN/RS485 devices and SANPO integrated joint motors.

  • 支持 CAN、RS485、FDCAN 设备通信验证Supports CAN, RS485, and FDCAN device communication validation
  • 实时曲线、收发日志、设备状态集中显示Live curves, TX/RX logs, and device status in one workspace
  • 适合研发调参、测试验证和现场排查Built for tuning, test validation, and field diagnosis
SANPO Studio interface
离线工具 · 本地运行Offline · Runs locally

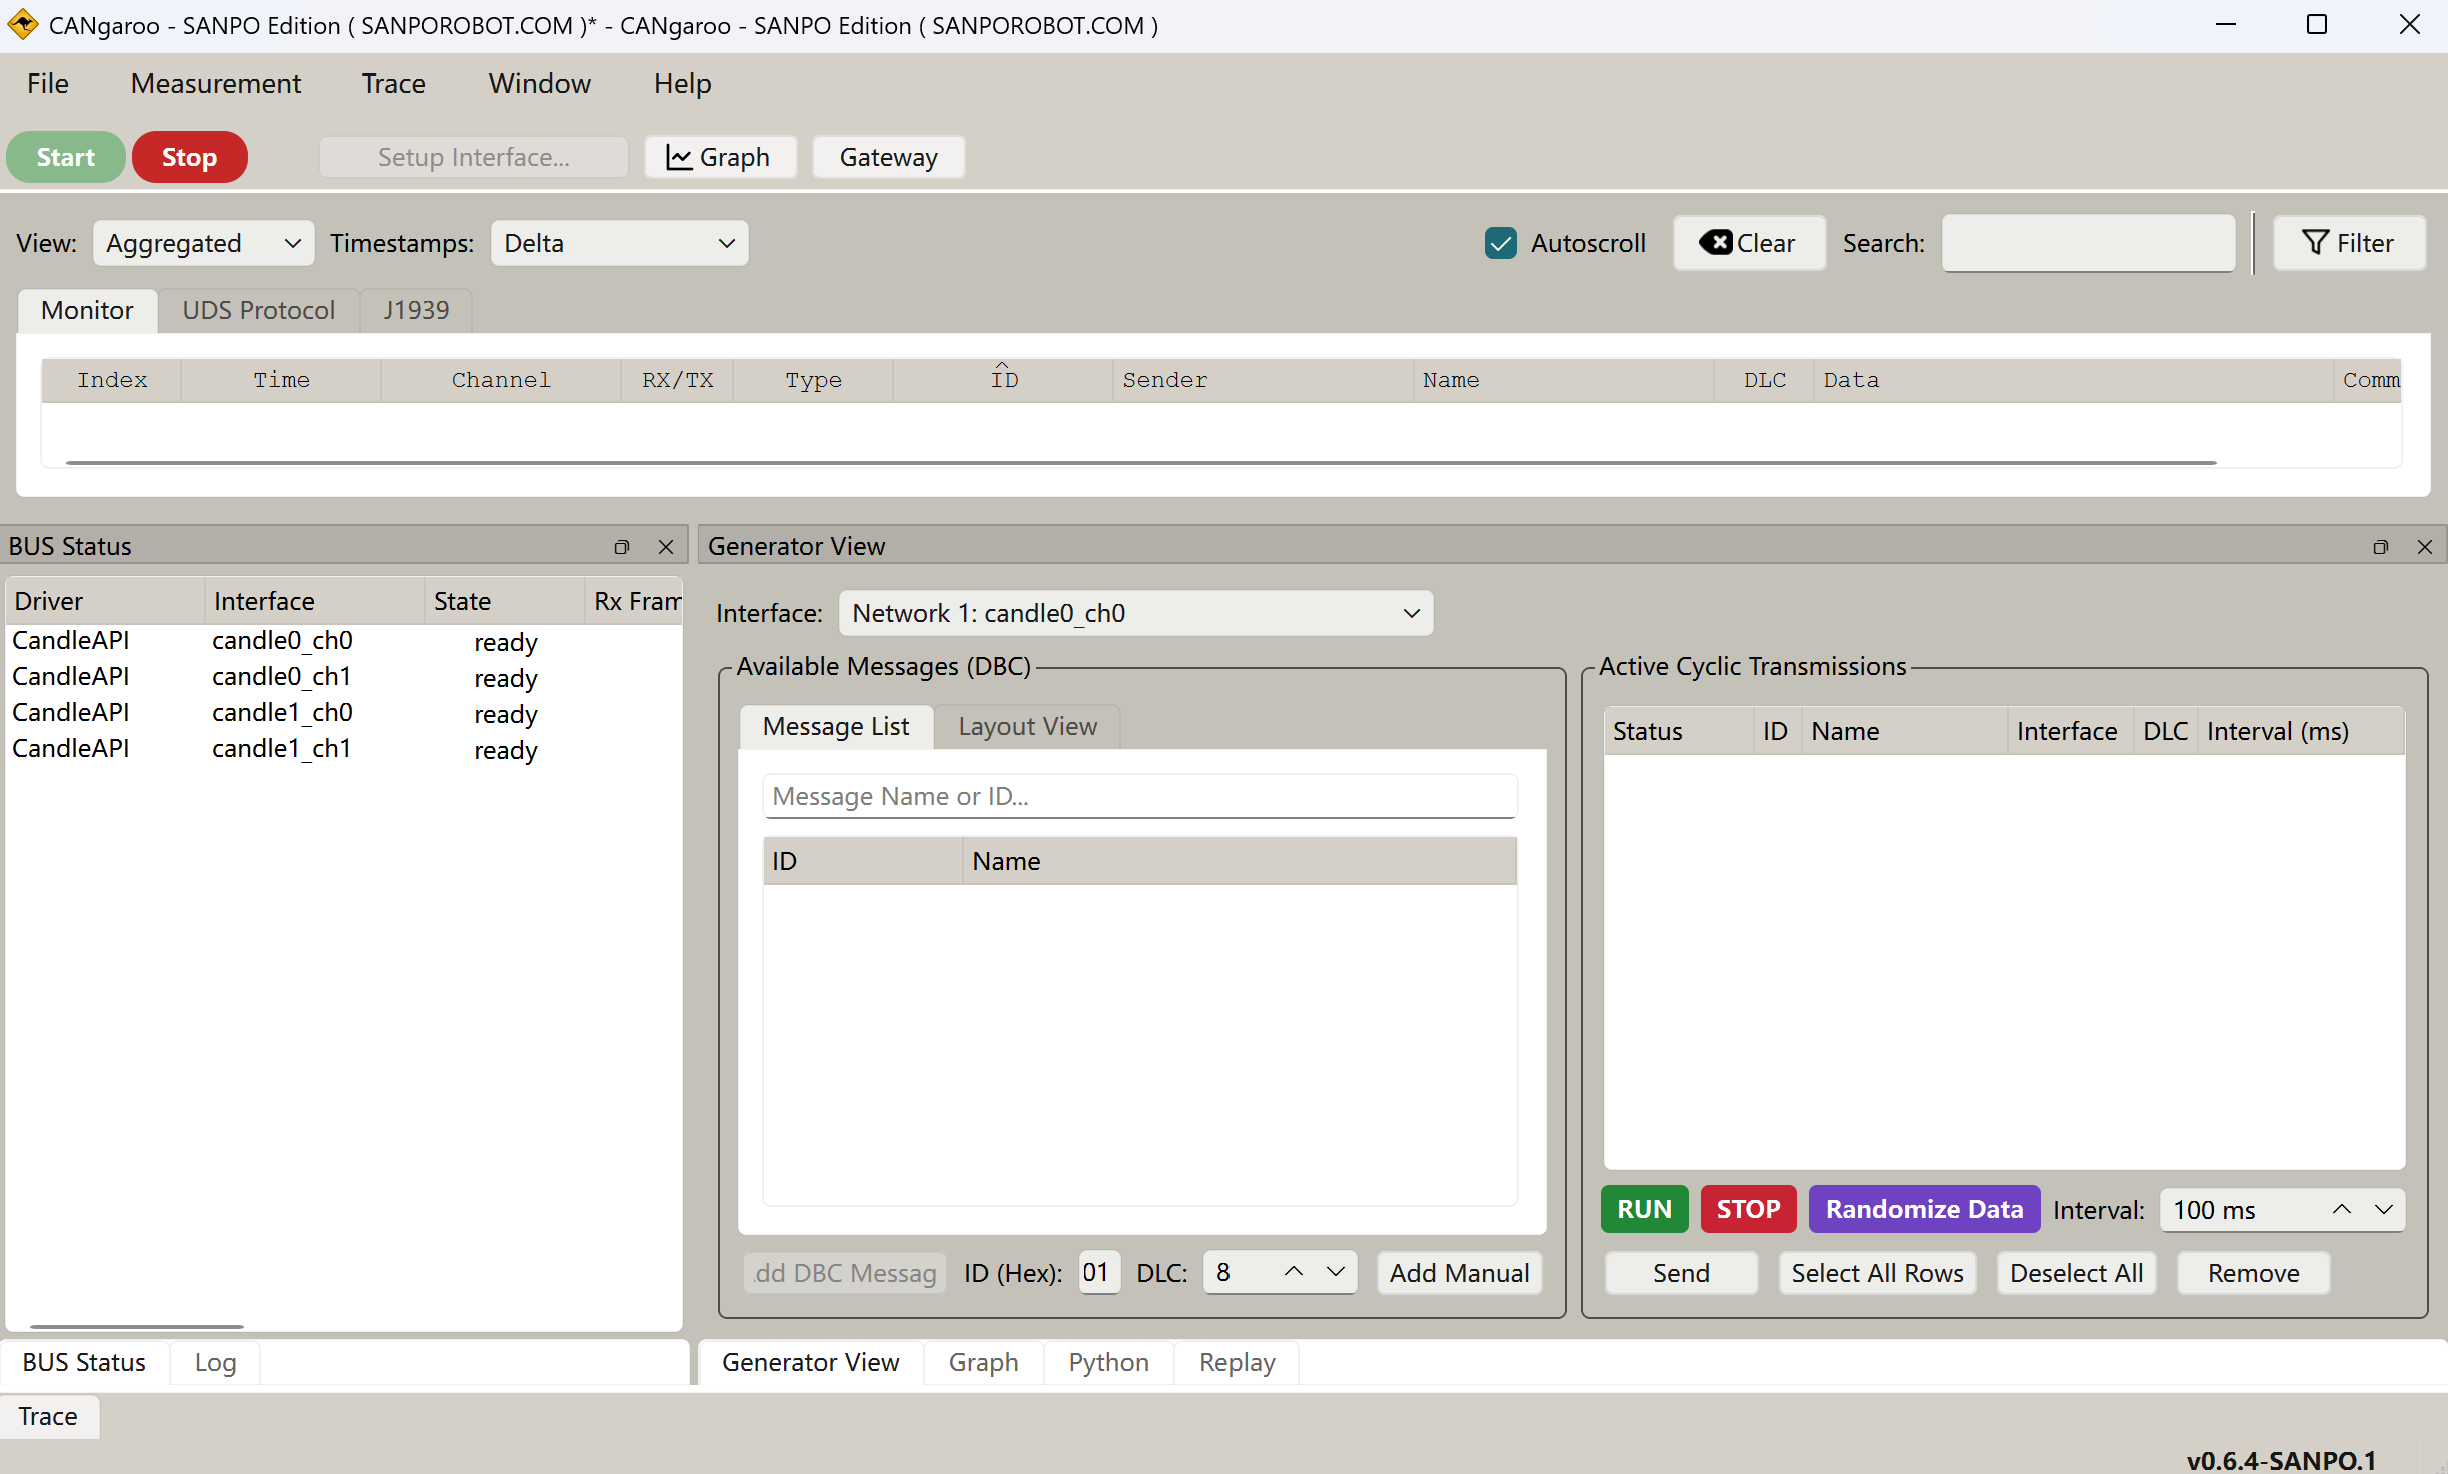
CANgaroo(SANPO 版)CANgaroo (SANPO Edition)

面向 CAN/FDCAN 总线监控与分析,适合开发验证、报文生成和现场诊断。A local CAN/FDCAN monitoring and analysis tool for validation, message generation, and field diagnostics.

  • 多通道总线监控与收发Multi-channel bus monitoring and transmission
  • DBC 报文解析与周期发送DBC message decoding and cyclic transmission
  • 搜索、过滤、曲线与回放Search, filtering, graphs, and replay
  • 源代码完全开源,适合研究学习 CAN/FDCAN 协议Fully open-source code for studying CAN/FDCAN protocols
CANgaroo SANPO Edition interface

共享资源中心Shared Resource Center

分享开发资源,样例程序,自定义协议插件等Share development resources, example programs, custom protocol plugins, and more.

显示 34 个资源Showing 34 resources
SANPO 官方SANPO OfficialSANPO SPINE样例程序SANPO SPINE Examples

通信参数查询和修改Query and Modify Communication Parameters

识别管理串口,查询固件版本、FDCAN/CAN 与 RS485 配置,并安全修改通信参数。Identify the management port, query firmware and bus settings, and safely update communication parameters.

适用版本Compatible Versions
升级版V8Upgrade V8
查看使用说明View Guide
SANPO 官方SANPO OfficialSANPO SPINE样例程序SANPO SPINE Examples

查询独立 RS485 透传串口Query the Dedicated RS485 Passthrough Ports

只读取 USB 描述符,不打开串口、不发送数据,快速区分两路管理口和四路 RS485 透传口。Read USB descriptors without opening ports or sending data, then distinguish management and RS485 passthrough ports.

适用版本Compatible Versions
升级版V8Upgrade V8
查看使用说明View Guide
SANPO 官方SANPO OfficialSANPO SPINE样例程序SANPO SPINE Examples

原生 gs_usb 经典 CAN 透传Native gs_usb Classic CAN Passthrough

通过 WinUSB/gs_usb 直接枚举、监听和发送经典 CAN 数据帧,不增加 SANPO 私有帧头。Enumerate, monitor, and send classic CAN frames directly through WinUSB/gs_usb without a SANPO wrapper.

适用版本Compatible Versions
升级版V8Upgrade V8
查看使用说明View Guide
SANPO 官方SANPO OfficialSANPO SPINE样例程序SANPO SPINE Examples

四路 gs_usb 接口枚举Enumerate Four gs_usb Channels

枚举两颗 SPINE MCU 的四路 CAN 接口,建立 USB 序列号、通道与实际接线的映射。Enumerate four CAN channels across both SPINE MCUs and map USB serials and channels to physical wiring.

适用版本Compatible Versions
升级版V8Upgrade V8
查看使用说明View Guide
SANPO 官方SANPO OfficialSANPO SPINE样例程序SANPO SPINE Examples

四路 CAN 总线状态安全查询Safe Four-channel CAN Status Query

自动识别两路管理口并查询四条 CAN 总线状态,不发送电机使能、位置或转矩命令。Discover both management ports and query all four CAN buses without sending motor enable, position, or torque commands.

适用版本Compatible Versions
升级版V8Upgrade V8
查看使用说明View Guide
SANPO 官方SANPO OfficialSANPO SPINE样例程序SANPO SPINE Examples

USB转RS485透传USB-to-RS485 Passthrough

通过四路独立 RS485 串口收发原始十六进制数据,并说明串口选择、波特率和报文长度。Send and receive raw hexadecimal data through the four independent RS485 ports with port, baud-rate, and frame-length guidance.

适用版本Compatible Versions
升级版V8Upgrade V8
查看使用说明View Guide
SANPO 官方SANPO OfficialSANPO SPINE样例程序SANPO SPINE Examples

通过 SPI 收发经典 CAN 标准帧Send and Receive Classic CAN Standard Frames over SPI

通过 SPI SHORT 协议发送经典 CAN 标准帧,默认使用只读状态查询验证链路。Send classic CAN standard frames over SPI SHORT, using a read-only status query for initial validation.

适用版本Compatible Versions
升级版V8Upgrade V8
查看使用说明View Guide
SANPO 官方SANPO OfficialSANPO SPINE 自定义固件SANPO SPINE Custom Firmware

基于原厂功能的二次开发框架Extension Framework with Factory Features

在 CustomerApp 中接入 USART3、I2C、ADC 外设和功能,同时保留原厂 USB、SPI、CAN/FDCAN、RS485 与管理功能。Add USART3, I2C, ADC, and customer tasks in CustomerApp while retaining USB, SPI, CAN/FDCAN, RS485, and management features.

适用版本Compatible Versions
升级版V8Upgrade V8
查看使用说明View Guide
SANPO 官方SANPO OfficialSANPO SPINE 自定义固件SANPO SPINE Custom Firmware

完全自定义固件开发框架(经典 CAN 标准帧)Fully Custom Firmware Framework (Classic CAN Standard Frames)

两路经典 CAN、11 位标准 ID、1 Mbit/s;默认只接收,并提供显式发送函数。Two classic CAN channels with 11-bit IDs at 1 Mbit/s; receive-only by default with an explicit send function.

适用版本Compatible Versions
升级版V8Upgrade V8
查看使用说明View Guide
SANPO 官方SANPO OfficialSANPO SPINE 自定义固件SANPO SPINE Custom Firmware

完全自定义固件开发框架(经典 CAN 扩展帧)Fully Custom Firmware Framework (Classic CAN Extended Frames)

两路经典 CAN、29 位扩展 ID、1 Mbit/s;包含接收验证、ID 位域设计和发送接入步骤。Two classic CAN channels with 29-bit IDs at 1 Mbit/s, with receive validation, ID layout, and send integration.

适用版本Compatible Versions
升级版V8Upgrade V8
查看使用说明View Guide
SANPO 官方SANPO OfficialSANPO SPINE 自定义固件SANPO SPINE Custom Firmware

完全自定义固件开发框架(FDCAN 标准帧)Fully Custom Firmware Framework (FDCAN Standard Frames)

11 位标准 ID,默认 1M/5M 和 BRS,说明合法 DLC、发送延迟补偿与总线验收。11-bit IDs with default 1M/5M and BRS, including legal DLCs, delay compensation, and bus validation.

适用版本Compatible Versions
升级版V8Upgrade V8
查看使用说明View Guide
SANPO 官方SANPO OfficialSANPO SPINE 自定义固件SANPO SPINE Custom Firmware

完全自定义固件(FDCAN 扩展帧)Fully Custom Firmware (FDCAN Extended Frames)

29 位扩展 ID,默认 1M/5M 和 BRS,包含扩展 ID 设计、接收验证和数据段排错。29-bit IDs with default 1M/5M and BRS, including ID design, receive validation, and data-phase troubleshooting.

适用版本Compatible Versions
升级版V8Upgrade V8
查看使用说明View Guide
SANPO 官方SANPO OfficialSANPO SPINE 自定义固件SANPO SPINE Custom Firmware

完全自定义固件开发框架(RS485 )Fully Custom Firmware Framework (RS485)

4 Mbit/s 半双工 RS485,方向切换、循环缓冲区、分帧、校验和超时处理。Two 4 Mbit/s half-duplex RS485 channels with direction control, ring buffers, framing, checksums, and timeouts.

适用版本Compatible Versions
升级版V8Upgrade V8
查看使用说明View Guide
SANPO 官方SANPO OfficialSANPO SPINE样例程序SANPO SPINE Examples

USB转CAN透传模式样例(SocketCAN 控制 小米CyberGear电机)USB-to-CAN Passthrough Sample (Control a Xiaomi CyberGear Motor with SocketCAN)

直接通过 gs_usb 控制 CyberGear,先完成设备枚举与映射,再显式启用运动。Control CyberGear directly over gs_usb after device enumeration and mapping, with explicit motion enablement.

适用版本Compatible Versions
升级版V8Upgrade V8
查看使用说明View Guide
SANPO 官方SANPO OfficialSANPO SPINE样例程序SANPO SPINE Examples

USB转CAN 协议模式样例(CyberGear) USB-to-CAN Protocol-mode Sample (CyberGear)

使用 V8 管理口 ET 报文控制 CyberGear,包含仅配置测试、参数说明与运动安全边界。Control CyberGear using V8 management-port ET frames, with configuration-only checks, parameters, and motion safety limits.

适用版本Compatible Versions
升级版V8Upgrade V8
查看使用说明View Guide
SANPO 官方SANPO OfficialSANPO SPINE样例程序SANPO SPINE Examples

SPI转CAN 控制样例(CyberGear)SPI-to-CAN Control Sample (CyberGear)

通过 SPI SHORT 协议发送 CyberGear 扩展 CAN 帧,包含只读链路检查和安全停止步骤。Send CyberGear extended CAN frames over SPI SHORT, with read-only link checks and safe stop procedures.

适用版本Compatible Versions
升级版V8Upgrade V8
查看使用说明View Guide
SANPO 官方SANPO OfficialSANPO SPINE样例程序SANPO SPINE Examples

CANopen控制样例CANopen Control Sample

读取节点状态并验证通道、Node-ID 和波特率,不发送位置、速度或转矩控制命令。Read node status and verify channel, Node-ID, and bitrate without sending position, speed, or torque commands.

适用版本Compatible Versions
升级版V8Upgrade V8
查看使用说明View Guide
SANPO 官方SANPO OfficialSANPO SPINE样例程序SANPO SPINE Examples

CANopen控制样例(H0-COR 小幅正弦运动)CANopen Control Sample (H0-COR Small-amplitude Sine Motion)

在安全探测通过后,以显式运动开关执行限幅正弦测试,并提供中断和停止流程。Run a limited sine test only after safe probing and explicit motion enablement, with interruption and stop procedures.

适用版本Compatible Versions
升级版V8Upgrade V8
查看使用说明View Guide
SANPO 官方SANPO OfficialSANPO SPINE样例程序SANPO SPINE Examples

PythonCAN 控制样例(CyberGear)PythonCAN Control Sample (CyberGear)

在 Windows 或 Linux 下通过 python-can-candle 访问四路 gs_usb,并建立电机通道映射。Access four gs_usb channels with python-can-candle on Windows or Linux and build a motor-channel map.

适用版本Compatible Versions
升级版V8Upgrade V8
查看使用说明View Guide
SANPO 官方SANPO OfficialSANPO SPINE样例程序SANPO SPINE Examples

翎控电机 Windows PythonCAN 直连样例Windows PythonCAN Direct CAN Sample for Lingkong Motor

通过 SANPO SPINE 的 gs_usb 接口在 Windows 下直接读取翎控电机状态,并执行带安全限制的单次位置测试。Read Lingkong motor status directly through the SANPO SPINE gs_usb interface on Windows and run a safety-limited single-position test.

适用版本Compatible Versions
升级版V8Upgrade V8
查看使用说明View Guide
SANPO 官方SANPO OfficialSANPO SPINE样例程序SANPO SPINE Examples

翎控机器臂 Windows PythonCAN 样例Windows PythonCAN Robot Arm Sample for Lingkong Motor

通过 PythonCAN 控制翎控机器臂电机,提供关节坐标换算、状态读取和受限位置测试。Control Lingkong robot-arm motors with PythonCAN, including joint-coordinate conversion, status reading, and safety-limited position testing.

适用版本Compatible Versions
升级版V8Upgrade V8
查看使用说明View Guide
SANPO 官方SANPO OfficialSANPO SPINE样例程序SANPO SPINE Examples

Linux SocketCAN 控制样例(CyberGear)Linux SocketCAN Control Sample (CyberGear)

配置 canX 接口、确认枚举映射,并通过 SocketCAN 接入一台或多台 CyberGear。Configure canX interfaces, verify enumeration mapping, and connect one or more CyberGear motors through SocketCAN.

适用版本Compatible Versions
升级版V8Upgrade V8
查看使用说明View Guide
SANPO 官方SANPO OfficialSANPO SPINE样例程序SANPO SPINE Examples

USB转RS485 透传样例(宇树 GM8010)USB-to-RS485 Passthrough Sample (Unitree GM8010)

使用独立 RS485 串口直接收发宇树协议,默认不运动,需显式启用小幅测试。Use an independent RS485 port for the Unitree protocol; motion is disabled by default and must be explicitly enabled.

适用版本Compatible Versions
升级版V8Upgrade V8
查看使用说明View Guide
SANPO 官方SANPO OfficialSANPO SPINE样例程序SANPO SPINE Examples

USB转RS485 协议模式控制样例(宇树 GM8010)USB-to-RS485 Protocol-mode Control Sample (Unitree GM8010)

通过管理口 RT 报文和指定 Channel 控制 GM8010,并在发送前恢复 4 Mbit/s 参数。Control GM8010 using management-port RT frames and a selected channel, restoring 4 Mbit/s settings before transmission.

适用版本Compatible Versions
升级版V8Upgrade V8
查看使用说明View Guide
SANPO 官方SANPO OfficialSANPO SPINE样例程序SANPO SPINE Examples

SPI转RS485 控制样例(宇树 GM8010)SPI-to-RS485 Control Sample (Unitree GM8010)

通过 SPI SHORT 协议向指定 RS485 通道发送 GM8010 报文,说明接线、通道和运动风险。Send GM8010 frames to a selected RS485 channel over SPI SHORT, with wiring, channel, and motion-risk guidance.

适用版本Compatible Versions
升级版V8Upgrade V8
查看使用说明View Guide
SANPO 官方SANPO OfficialSANPO J8108-R8 使用样例SANPO J8108-R8 Examples

USB 直连维护与调试Direct USB Maintenance and Testing

直接连接电机 USB 调试口,完成状态读取、参数配置、受控试转和固件维护。Connect directly to the motor USB debug port for status, configuration, controlled motion, and firmware maintenance.

适用版本Compatible Versions
SANPO J8108-R8SANPO J8108-R8
打开 SANPO StudioOpen SANPO Studio
SANPO 官方SANPO OfficialSANPO J8108-R8 使用样例SANPO J8108-R8 Examples

FDCAN 单/多轴电机控制FDCAN Single-/Multi-Axis Motor Control

使用 SANPO SPINE 连接电机,并使用 FDCAN 单/多轴控制协议调试电机。Connect the motor through SANPO SPINE and use the FDCAN single-/multi-axis control protocol to debug the motor.

适用版本Compatible Versions
SANPO J8108-R8SANPO J8108-R8
打开 SANPO StudioOpen SANPO Studio
SANPO 官方SANPO OfficialSANPO J8108-R8 使用样例SANPO J8108-R8 Examples

经典 CAN/RS485 协议电机控制Classic CAN/RS485 Motor Control

使用 SANPO SPINE 连接电机,并使用经典 CAN/RS485 协议控制电机,例如 MIT CAN 协议、小米 CyberGear 电机 CAN 协议、宇树 GM8010 电机 RS485 协议等。Connect the motor through SANPO SPINE and control it with Classic CAN/RS485 protocols, such as MIT CAN, Xiaomi CyberGear CAN, and Unitree GM8010 RS485.

适用版本Compatible Versions
SANPO J8108-R8SANPO J8108-R8
打开 SANPO StudioOpen SANPO Studio
开源社区提供Open-source CommunitySANPO J8108-R8 自定义协议插件SANPO J8108-R8 Custom Protocol Plugins

MIT 兼容协议插件MIT-Compatible Protocol Plugin

兼容 MIT Mini Cheetah 经典 CAN 五参数控制格式。插件由开源社区提供并随当前出厂固件预装。Compatible with the MIT Mini Cheetah five-parameter Classic CAN control format. This plugin is provided by the open-source community and preinstalled in the current factory firmware.

适用版本Compatible Versions
SANPO J8108-R8SANPO J8108-R8
作者:社区用户
查看插件说明View Plugin Guide
开源社区提供Open-source CommunitySANPO J8108-R8 自定义协议插件SANPO J8108-R8 Custom Protocol Plugins

CyberGear 兼容协议插件CyberGear-Compatible Protocol Plugin

兼容 小米CyberGear 上位机 的 29 位扩展 CAN 报文和常用参数控制。插件由开源社区提供、随当前出厂固件预装。Compatible with the 29-bit extended CAN frames and common parameter controls used by Xiaomi CyberGear host software. This plugin is provided by the open-source community and preinstalled in the current factory firmware.

适用版本Compatible Versions
SANPO J8108-R8SANPO J8108-R8
作者:社区用户
查看插件说明View Plugin Guide
开源社区提供Open-source CommunitySANPO J8108-R8 自定义协议插件SANPO J8108-R8 Custom Protocol Plugins

GM8010 兼容协议插件GM8010-Compatible Protocol Plugin

兼容宇树 GM8010 上位机的 RS485 请求、反馈与五参数控制格式。插件由开源社区提供并随当前出厂固件预装。Compatible with the RS485 request, feedback, and five-parameter control formats used by Unitree GM8010 host software. This plugin is provided by the open-source community and preinstalled in the current factory firmware.

适用版本Compatible Versions
SANPO J8108-R8SANPO J8108-R8
作者:社区用户
查看插件说明View Plugin Guide
开源社区提供Open-source CommunitySANPO J8108-R8 自定义协议插件SANPO J8108-R8 Custom Protocol Plugins

OpenARM 兼容协议插件OpenARM-Compatible Protocol Plugin

面向 OpenARM 控制报文的社区兼容插件。插件由开源社区提供,标准出厂固件不预装,可自行安装。A community compatibility plugin for OpenARM control frames. This plugin is provided by the open-source community, is not included in the standard factory firmware, and can be installed separately.

适用版本Compatible Versions
SANPO J8108-R8SANPO J8108-R8
作者:社区用户
查看插件说明View Plugin Guide
开源社区提供Open-source CommunitySANPO J8108-R8 自定义协议插件SANPO J8108-R8 Custom Protocol Plugins

CANopen 兼容协议插件CANopen-Compatible Protocol Plugin

面向 CANopen CiA 402 的兼容协议插件。插件由开源社区提供,标准出厂固件不预装,可自行安装。A CANopen CiA 402 compatibility protocol plugin. This plugin is provided by the open-source community, is not included in the standard factory firmware, and can be installed separately.

适用版本Compatible Versions
SANPO J8108-R8SANPO J8108-R8
作者:社区用户
查看插件说明View Plugin Guide

上传资源Upload Resource

分享源代码、工程文件和使用说明。Share source code, project files, and guides.

立即上传Upload Now